
|
CGMES_3_0_0
|
|
|
CGMES_3_0_0
|
Synchronous machine detailed modelling types are defined by the combination of the attributes SynchronousMachineTimeConstantReactance.modelType and SynchronousMachineTimeConstantReactance.rotorType. Parameter details: More...
#include <SynchronousMachineTimeConstantReactance.hpp>
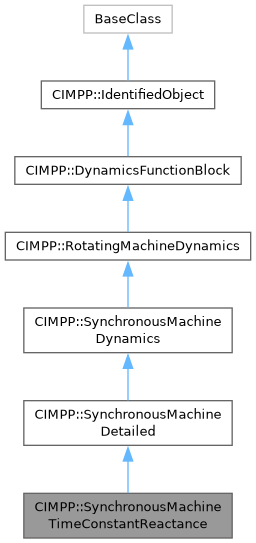
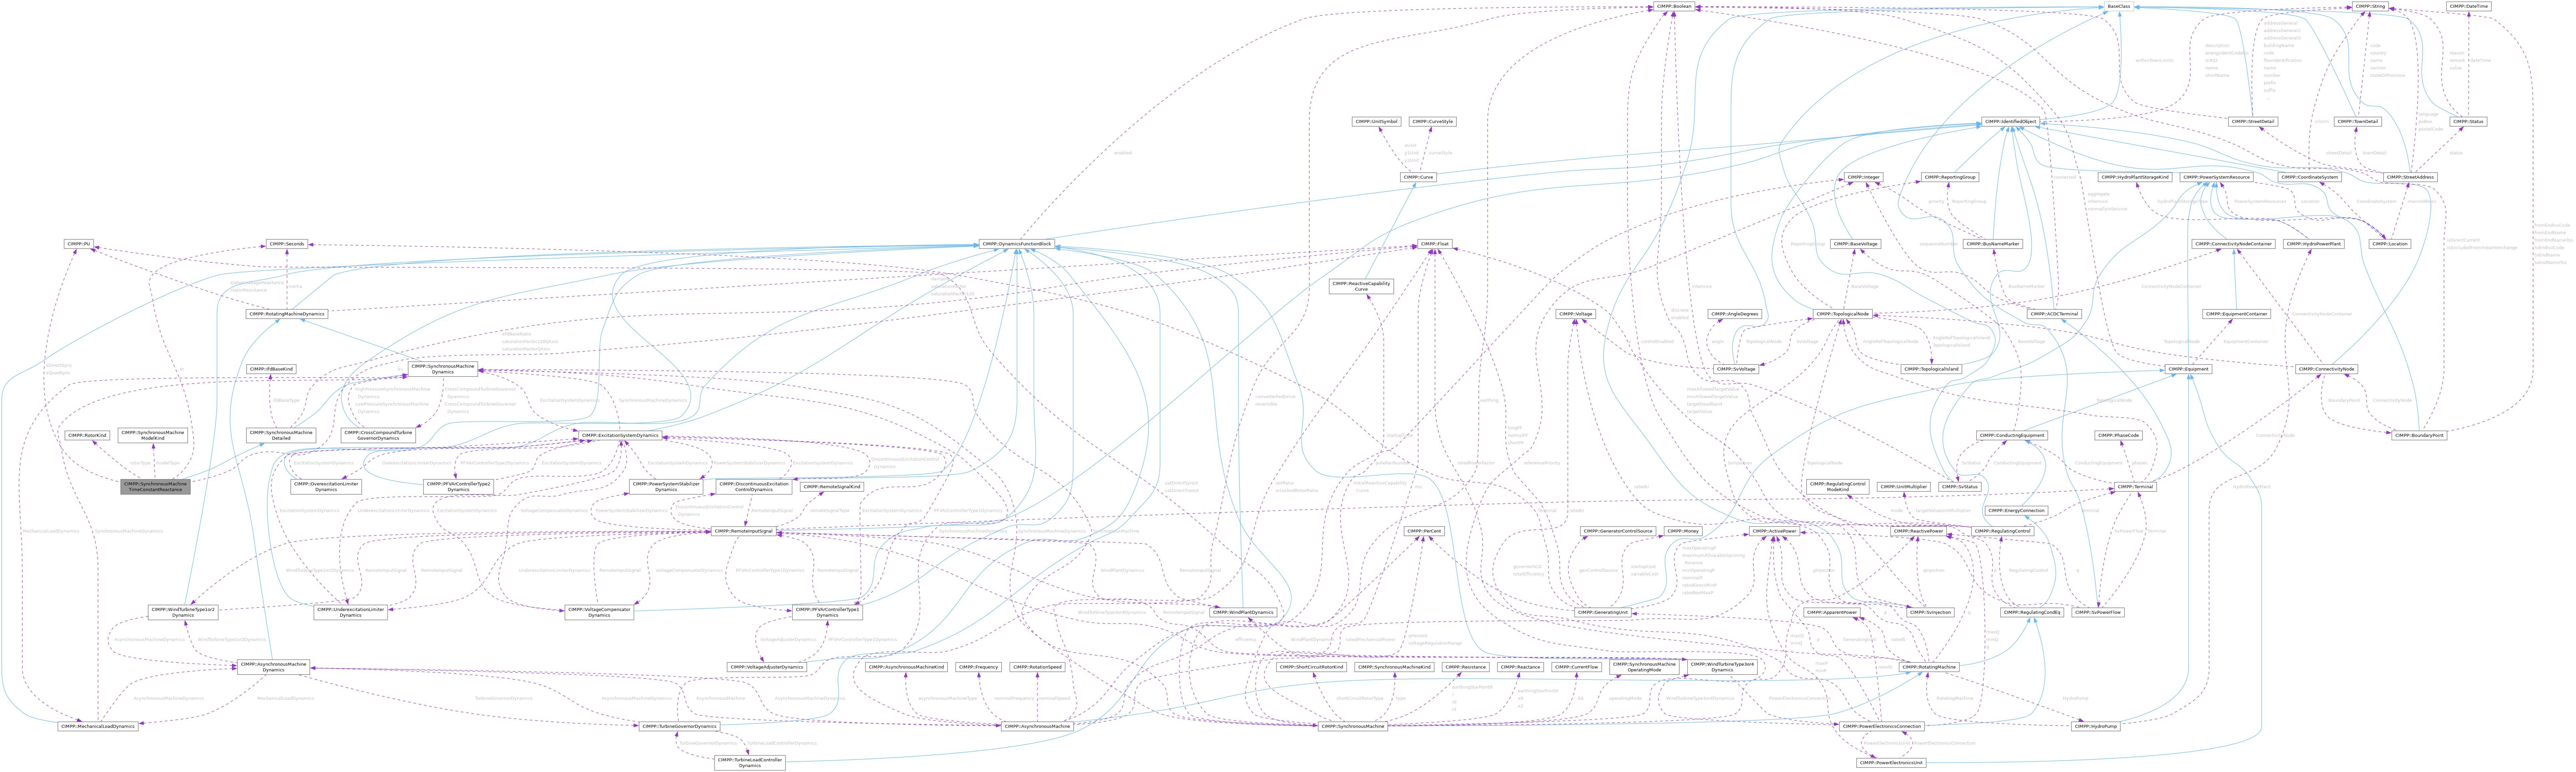
Public Attributes | |
| CIMPP::Float | ks |
| Saturation loading correction factor (Ks) (>= 0). Used only by type J model. Typical value = 0. Default: 0.0. | |
| CIMPP::SynchronousMachineModelKind | modelType |
| Type of synchronous machine model used in dynamic simulation applications. Default: 0. | |
| CIMPP::RotorKind | rotorType |
| Type of rotor on physical machine. Default: 0. | |
| CIMPP::Seconds | tc |
| Damping time constant for Canay reactance (>= 0). Typical value = 0. Default: 0.0. | |
| CIMPP::PU | xDirectSync |
| Direct-axis transient rotor time constant (T`do) (> SynchronousMachineTimeConstantReactance.tppdo). Typical value = 5. Default: 0.0 */ CIMPP::Seconds tpdo;. | |
| CIMPP::PU | xQuadSync |
| Direct-axis transient reactance (unsaturated) (X`d) (>= SynchronousMachineTimeConstantReactance.xDirectSubtrans). Typical value = 0,5. Default: 0.0 */ CIMPP::PU xDirectTrans;. | |
| Public Attributes inherited from CIMPP::SynchronousMachineDetailed | |
| CIMPP::Float | efdBaseRatio |
| Ratio (exciter voltage/generator voltage) of Efd bases of exciter and generator models (> 0). Typical value = 1. Default: 0.0. | |
| CIMPP::IfdBaseKind | ifdBaseType |
| Excitation base system mode. It should be equal to the value of WLMDV given by the user. WLMDV is the PU ratio between the field voltage and the excitation current: Efd = WLMDV x Ifd. Typical value = ifag. Default: 0. | |
| CIMPP::Float | saturationFactor120QAxis |
| Quadrature-axis saturation factor at 120% of rated terminal voltage (S12q) (>= SynchonousMachineDetailed.saturationFactorQAxis). Typical value = 0,12. Default: 0.0. | |
| CIMPP::Float | saturationFactorQAxis |
| Quadrature-axis saturation factor at rated terminal voltage (S1q) (>= 0). Typical value = 0,02. Default: 0.0. | |
| Public Attributes inherited from CIMPP::SynchronousMachineDynamics | |
| CIMPP::CrossCompoundTurbineGovernorDynamics * | CrossCompoundTurbineGovernorDyanmics |
| The cross-compound turbine governor with which this high-pressure synchronous machine is associated. Default: nullptr. | |
| CIMPP::CrossCompoundTurbineGovernorDynamics * | CrossCompoundTurbineGovernorDynamics |
| The cross-compound turbine governor with which this low-pressure synchronous machine is associated. Default: nullptr. | |
| CIMPP::ExcitationSystemDynamics * | ExcitationSystemDynamics |
| Excitation system model associated with this synchronous machine model. Default: nullptr. | |
| CIMPP::MechanicalLoadDynamics * | MechanicalLoadDynamics |
| Compensation of voltage compensator`s generator for current flow out of this generator. Default: {} */ std::list<CIMPP::GenICompensationForGenJ*> GenICompensationForGenJ;. | |
| CIMPP::SynchronousMachine * | SynchronousMachine |
| Synchronous machine to which synchronous machine dynamics model applies. Default: nullptr. | |
| std::list< CIMPP::TurbineGovernorDynamics * > | TurbineGovernorDynamics |
| Turbine-governor model associated with this synchronous machine model. Multiplicity of greater than one is intended to support hydro units that have multiple turbines on one generator. Default: {}. | |
| Public Attributes inherited from CIMPP::RotatingMachineDynamics | |
| CIMPP::Float | damping |
| Damping torque coefficient (D) (>= 0). A proportionality constant that, when multiplied by the angular velocity of the rotor poles with respect to the magnetic field (frequency), results in the damping torque. This value is often zero when the sources of damping torques (generator damper windings, load damping effects, etc.) are modelled in detail. Typical value = 0. Default: 0.0. | |
| CIMPP::Seconds | inertia |
| Inertia constant of generator or motor and mechanical load (H) (> 0). This is the specification for the stored energy in the rotating mass when operating at rated speed. For a generator, this includes the generator plus all other elements (turbine, exciter) on the same shaft and has units of MW x s. For a motor, it includes the motor plus its mechanical load. Conventional units are PU on the generator MVA base, usually expressed as MW x s / MVA or just s. This value is used in the accelerating power reference frame for operator training simulator solutions. Typical value = 3. Default: 0.0. | |
| CIMPP::Float | saturationFactor |
| Saturation factor at rated terminal voltage (S1) (>= 0). Not used by simplified model. Defined by defined by S(E1) in the SynchronousMachineSaturationParameters diagram. Typical value = 0,02. Default: 0.0. | |
| CIMPP::Float | saturationFactor120 |
| Saturation factor at 120% of rated terminal voltage (S12) (>= RotatingMachineDynamics.saturationFactor). Not used by the simplified model, defined by S(E2) in the SynchronousMachineSaturationParameters diagram. Typical value = 0,12. Default: 0.0. | |
| CIMPP::PU | statorLeakageReactance |
| Stator leakage reactance (Xl) (>= 0). Typical value = 0,15. Default: 0.0. | |
| CIMPP::PU | statorResistance |
| Stator (armature) resistance (Rs) (>= 0). Typical value = 0,005. Default: 0.0. | |
| Public Attributes inherited from CIMPP::DynamicsFunctionBlock | |
| CIMPP::Boolean | enabled |
| Function block used indicator. true = use of function block is enabled false = use of function block is disabled. Default: false. | |
| Public Attributes inherited from CIMPP::IdentifiedObject | |
| std::list< CIMPP::DiagramObject * > | DiagramObjects |
| The diagram objects that are associated with the domain object. Default: {}. | |
| CIMPP::String | description |
| The description is a free human readable text describing or naming the object. It may be non unique and may not correlate to a naming hierarchy. Default: "". | |
| CIMPP::String | energyIdentCodeEic |
| The attribute is used for an exchange of the EIC code (Energy identification Code). The length of the string is 16 characters as defined by the EIC code. For details on EIC scheme please refer to ENTSO-E web site. Default: "". | |
| CIMPP::String | mRID |
| Master resource identifier issued by a model authority. The mRID is unique within an exchange context. Global uniqueness is easily achieved by using a UUID, as specified in RFC 4122, for the mRID. The use of UUID is strongly recommended. For CIMXML data files in RDF syntax conforming to IEC 61970-552, the mRID is mapped to rdf:ID or rdf:about attributes that identify CIM object elements. Default: "". | |
| CIMPP::String | name |
| The name is any free human readable and possibly non unique text naming the object. Default: "". | |
| CIMPP::String | shortName |
| The attribute is used for an exchange of a human readable short name with length of the string 12 characters maximum. Default: "". | |
Additional Inherited Members | |
| Public Member Functions inherited from CIMPP::SynchronousMachineDetailed | |
| const char * | debugString () const override |
| const std::list< std::string > & | getAttributeNames () const override |
| const std::string & | getClassNamespaceUrl () const override |
| const std::string & | getAttributeNamespaceUrl (const std::string &attrName) const override |
| const std::list< CGMESProfile > & | getPossibleProfiles () const override |
| const CGMESProfile & | getRecommendedProfile () const override |
| const std::list< CGMESProfile > & | getPossibleAttributeProfiles (const std::string &attrName) const override |
| const std::list< CGMESProfile > & | getPossibleProfilesIncludingAttributes () const override |
| void | addPrimitiveGetFnsToMap (std::map< std::string, get_function > &get_map) const override |
| void | addClassGetFnsToMap (std::map< std::string, class_get_function > &get_map) const override |
| void | addEnumGetFnsToMap (std::map< std::string, get_function > &get_map) const override |
| bool | isAssignableFrom (BaseClass *otherObject) const override |
| Public Member Functions inherited from CIMPP::SynchronousMachineDynamics | |
| const char * | debugString () const override |
| const std::list< std::string > & | getAttributeNames () const override |
| const std::string & | getClassNamespaceUrl () const override |
| const std::string & | getAttributeNamespaceUrl (const std::string &attrName) const override |
| const std::list< CGMESProfile > & | getPossibleProfiles () const override |
| const CGMESProfile & | getRecommendedProfile () const override |
| const std::list< CGMESProfile > & | getPossibleAttributeProfiles (const std::string &attrName) const override |
| const std::list< CGMESProfile > & | getPossibleProfilesIncludingAttributes () const override |
| void | addPrimitiveGetFnsToMap (std::map< std::string, get_function > &get_map) const override |
| void | addClassGetFnsToMap (std::map< std::string, class_get_function > &get_map) const override |
| void | addEnumGetFnsToMap (std::map< std::string, get_function > &get_map) const override |
| bool | isAssignableFrom (BaseClass *otherObject) const override |
| Public Member Functions inherited from BaseClass | |
| void | setRdfid (const std::string &id) |
| std::string | getRdfid () const |
| Static Public Member Functions inherited from CIMPP::SynchronousMachineDetailed | |
| static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
| static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
| static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
| static const BaseClassDefiner | declare () |
| Static Public Member Functions inherited from CIMPP::SynchronousMachineDynamics | |
| static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
| static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
| static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
| static const BaseClassDefiner | declare () |
| Static Public Member Functions inherited from CIMPP::RotatingMachineDynamics | |
| static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
| static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
| static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
| static const BaseClassDefiner | declare () |
| Static Public Member Functions inherited from CIMPP::DynamicsFunctionBlock | |
| static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
| static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
| static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
| static const BaseClassDefiner | declare () |
| Static Public Member Functions inherited from CIMPP::IdentifiedObject | |
| static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
| static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
| static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
| static const BaseClassDefiner | declare () |
| Static Public Member Functions inherited from BaseClass | |
| static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
| static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
| static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
| static const CIMPP::BaseClassDefiner | declare () |
| Static Public Attributes inherited from CIMPP::SynchronousMachineDetailed | |
| static const char | debugName [] = "SynchronousMachineDetailed" |
| Static Public Attributes inherited from CIMPP::SynchronousMachineDynamics | |
| static const char | debugName [] = "SynchronousMachineDynamics" |
| Static Public Attributes inherited from CIMPP::RotatingMachineDynamics | |
| static const char | debugName [] = "RotatingMachineDynamics" |
| Static Public Attributes inherited from CIMPP::DynamicsFunctionBlock | |
| static const char | debugName [] = "DynamicsFunctionBlock" |
| Static Public Attributes inherited from CIMPP::IdentifiedObject | |
| static const char | debugName [] = "IdentifiedObject" |
| Static Public Attributes inherited from BaseClass | |
| static const char | debugName [] = "BaseClass" |
| Protected Member Functions inherited from CIMPP::SynchronousMachineDetailed | |
| std::map< std::string, AttrDetails > | allAttrDetailsMap () const override |
| Protected Member Functions inherited from CIMPP::SynchronousMachineDynamics | |
| std::map< std::string, AttrDetails > | allAttrDetailsMap () const override |
Synchronous machine detailed modelling types are defined by the combination of the attributes SynchronousMachineTimeConstantReactance.modelType and SynchronousMachineTimeConstantReactance.rotorType. Parameter details:
- RotatingMachine.ratedS (MVAbase); - RotatingMachineDynamics.damping (D); - RotatingMachineDynamics.inertia (H); - RotatingMachineDynamics.saturationFactor (S1); - RotatingMachineDynamics.saturationFactor120 (S12); - RotatingMachineDynamics.statorLeakageReactance (Xl); - RotatingMachineDynamics.statorResistance (Rs); - SynchronousMachineTimeConstantReactance.ks (Ks); - SynchronousMachineDetailed.saturationFactorQAxis (S1q); - SynchronousMachineDetailed.saturationFactor120QAxis (S12q); - SynchronousMachineDetailed.efdBaseRatio; - SynchronousMachineDetailed.ifdBaseType; - .xDirectSync (Xd); - .xDirectTrans (X'd); - .xDirectSubtrans (X''d); - .xQuadSync (Xq); - .xQuadTrans (X'q); - .xQuadSubtrans (X''q); - .tpdo (T'do); - .tppdo (T''do); - .tpqo (T'qo); - .tppqo (T''qo); - .tc.
| CIMPP::PU CIMPP::SynchronousMachineTimeConstantReactance::xDirectSync |
Direct-axis transient rotor time constant (T`do) (> SynchronousMachineTimeConstantReactance.tppdo). Typical value = 5. Default: 0.0 */ CIMPP::Seconds tpdo;.
/** Direct-axis subtransient rotor time constant (T``do) (> 0). Typical value = 0,03. Default: 0.0 */ CIMPP::Seconds tppdo;
/** Quadrature-axis subtransient rotor time constant (T``qo) (> 0). Typical value = 0,03. Default: 0.0 */ CIMPP::Seconds tppqo;
/** Quadrature-axis transient rotor time constant (T`qo) (> SynchronousMachineTimeConstantReactance.tppqo). Typical value = 0,5. Default: 0.0 */ CIMPP::Seconds tpqo;
/** Direct-axis subtransient reactance (unsaturated) (X``d) (> RotatingMachineDynamics.statorLeakageReactance). Typical value = 0,2. Default: 0.0 */ CIMPP::PU xDirectSubtrans;
/** Direct-axis synchronous reactance (Xd) (>= SynchronousMachineTimeConstantReactance.xDirectTrans). The quotient of a sustained value of that AC component of armature voltage that is produced by the total direct-axis flux due to direct-axis armature current and the value of the AC component of this current, the machine running at rated speed. Typical value = 1,8. Default: 0.0
| CIMPP::PU CIMPP::SynchronousMachineTimeConstantReactance::xQuadSync |
Direct-axis transient reactance (unsaturated) (X`d) (>= SynchronousMachineTimeConstantReactance.xDirectSubtrans). Typical value = 0,5. Default: 0.0 */ CIMPP::PU xDirectTrans;.
/** Quadrature-axis subtransient reactance (X``q) (> RotatingMachineDynamics.statorLeakageReactance). Typical value = 0,2. Default: 0.0 */ CIMPP::PU xQuadSubtrans;
/** Quadrature-axis synchronous reactance (Xq) (>= SynchronousMachineTimeConstantReactance.xQuadTrans). The ratio of the component of reactive armature voltage, due to the quadrature-axis component of armature current, to this component of current, under steady state conditions and at rated frequency. Typical value = 1,6. Default: 0.0
 1.15.0