|
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const CIMPP::BaseClassDefiner | declare () |
|
|
std::list< CIMPP::WindDynamicsLookupTable * > | WindDynamicsLookupTable |
| | The wind dynamics lookup table associated with this P control type 3 model. Default: {}.
|
|
CIMPP::WindTurbineType3IEC * | WindTurbineType3IEC |
| | Wind turbine type 3 model with which this wind control P type 3 model is associated. Default: nullptr.
|
|
CIMPP::PU | dpmax |
| | Maximum wind turbine power ramp rate (dpmax). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | dprefmax |
| | Maximum ramp rate of wind turbine reference power (dprefmax). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | dprefmin |
| | Minimum ramp rate of wind turbine reference power (dprefmin). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | dthetamax |
| | Ramp limitation of torque, required in some grid codes (dtmax). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | dthetamaxuvrt |
| | Limitation of torque rise rate during UVRT (dthetamaxUVRT). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | kdtd |
| | Gain for active drive train damping (KDTD). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | kip |
| | PI controller integration parameter (KIp). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | kpp |
| | PI controller proportional gain (KPp). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::Boolean | mpuvrt |
| | Enable UVRT power control mode (MpUVRT). It is a project-dependent parameter. true = voltage control (1 in the IEC model) false = reactive power control (0 in the IEC model). Default: false.
|
|
CIMPP::PU | omegadtd |
| | Active drive train damping frequency (omegaDTD). It can be calculated from two mass model parameters. It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | omegaoffset |
| | Offset to reference value that limits controller action during rotor speed changes (omegaoffset). It is a case-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | pdtdmax |
| | Maximum active drive train damping power (pDTDmax). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::Seconds | tdvs |
| | Time delay after deep voltage sags (TDVS) (>= 0). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | thetaemin |
| | Minimum electrical generator torque (temin). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | thetauscale |
| | Voltage scaling factor of reset-torque (tuscale). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::Seconds | tomegafiltp3 |
| | Filter time constant for generator speed measurement (Tomegafiltp3) (>= 0). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::Seconds | tomegaref |
| | Time constant in speed reference filter (Tomega,ref) (>= 0). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::Seconds | tpfiltp3 |
| | Filter time constant for power measurement (Tpfiltp3) (>= 0). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | tpord |
| | Time constant in power order lag (Tpord). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::Seconds | tufiltp3 |
| | Filter time constant for voltage measurement (Tufiltp3) (>= 0). It is a type-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | udvs |
| | Voltage limit for hold UVRT status after deep voltage sags (uDVS). It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::PU | updip |
| | Voltage dip threshold for P-control (uPdip). Part of turbine control, often different (e.g 0.8) from converter thresholds. It is a project-dependent parameter. Default: 0.0.
|
|
CIMPP::Float | zeta |
| | Coefficient for active drive train damping (zeta). It is a type-dependent parameter. Default: 0.0.
|
|
std::list< CIMPP::DiagramObject * > | DiagramObjects |
| | The diagram objects that are associated with the domain object. Default: {}.
|
|
CIMPP::String | description |
| | The description is a free human readable text describing or naming the object. It may be non unique and may not correlate to a naming hierarchy. Default: "".
|
|
CIMPP::String | energyIdentCodeEic |
| | The attribute is used for an exchange of the EIC code (Energy identification Code). The length of the string is 16 characters as defined by the EIC code. For details on EIC scheme please refer to ENTSO-E web site. Default: "".
|
|
CIMPP::String | mRID |
| | Master resource identifier issued by a model authority. The mRID is unique within an exchange context. Global uniqueness is easily achieved by using a UUID, as specified in RFC 4122, for the mRID. The use of UUID is strongly recommended. For CIMXML data files in RDF syntax conforming to IEC 61970-552, the mRID is mapped to rdf:ID or rdf:about attributes that identify CIM object elements. Default: "".
|
|
CIMPP::String | name |
| | The name is any free human readable and possibly non unique text naming the object. Default: "".
|
|
CIMPP::String | shortName |
| | The attribute is used for an exchange of a human readable short name with length of the string 12 characters maximum. Default: "".
|
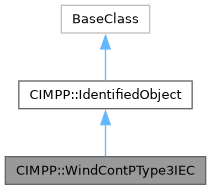
P control model type 3. Reference: IEC 61400-27-1:2015, 5.6.5.4.

 1.15.0