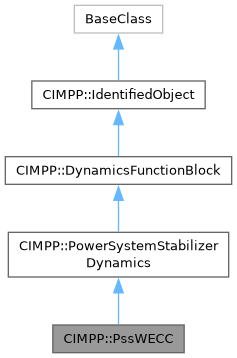
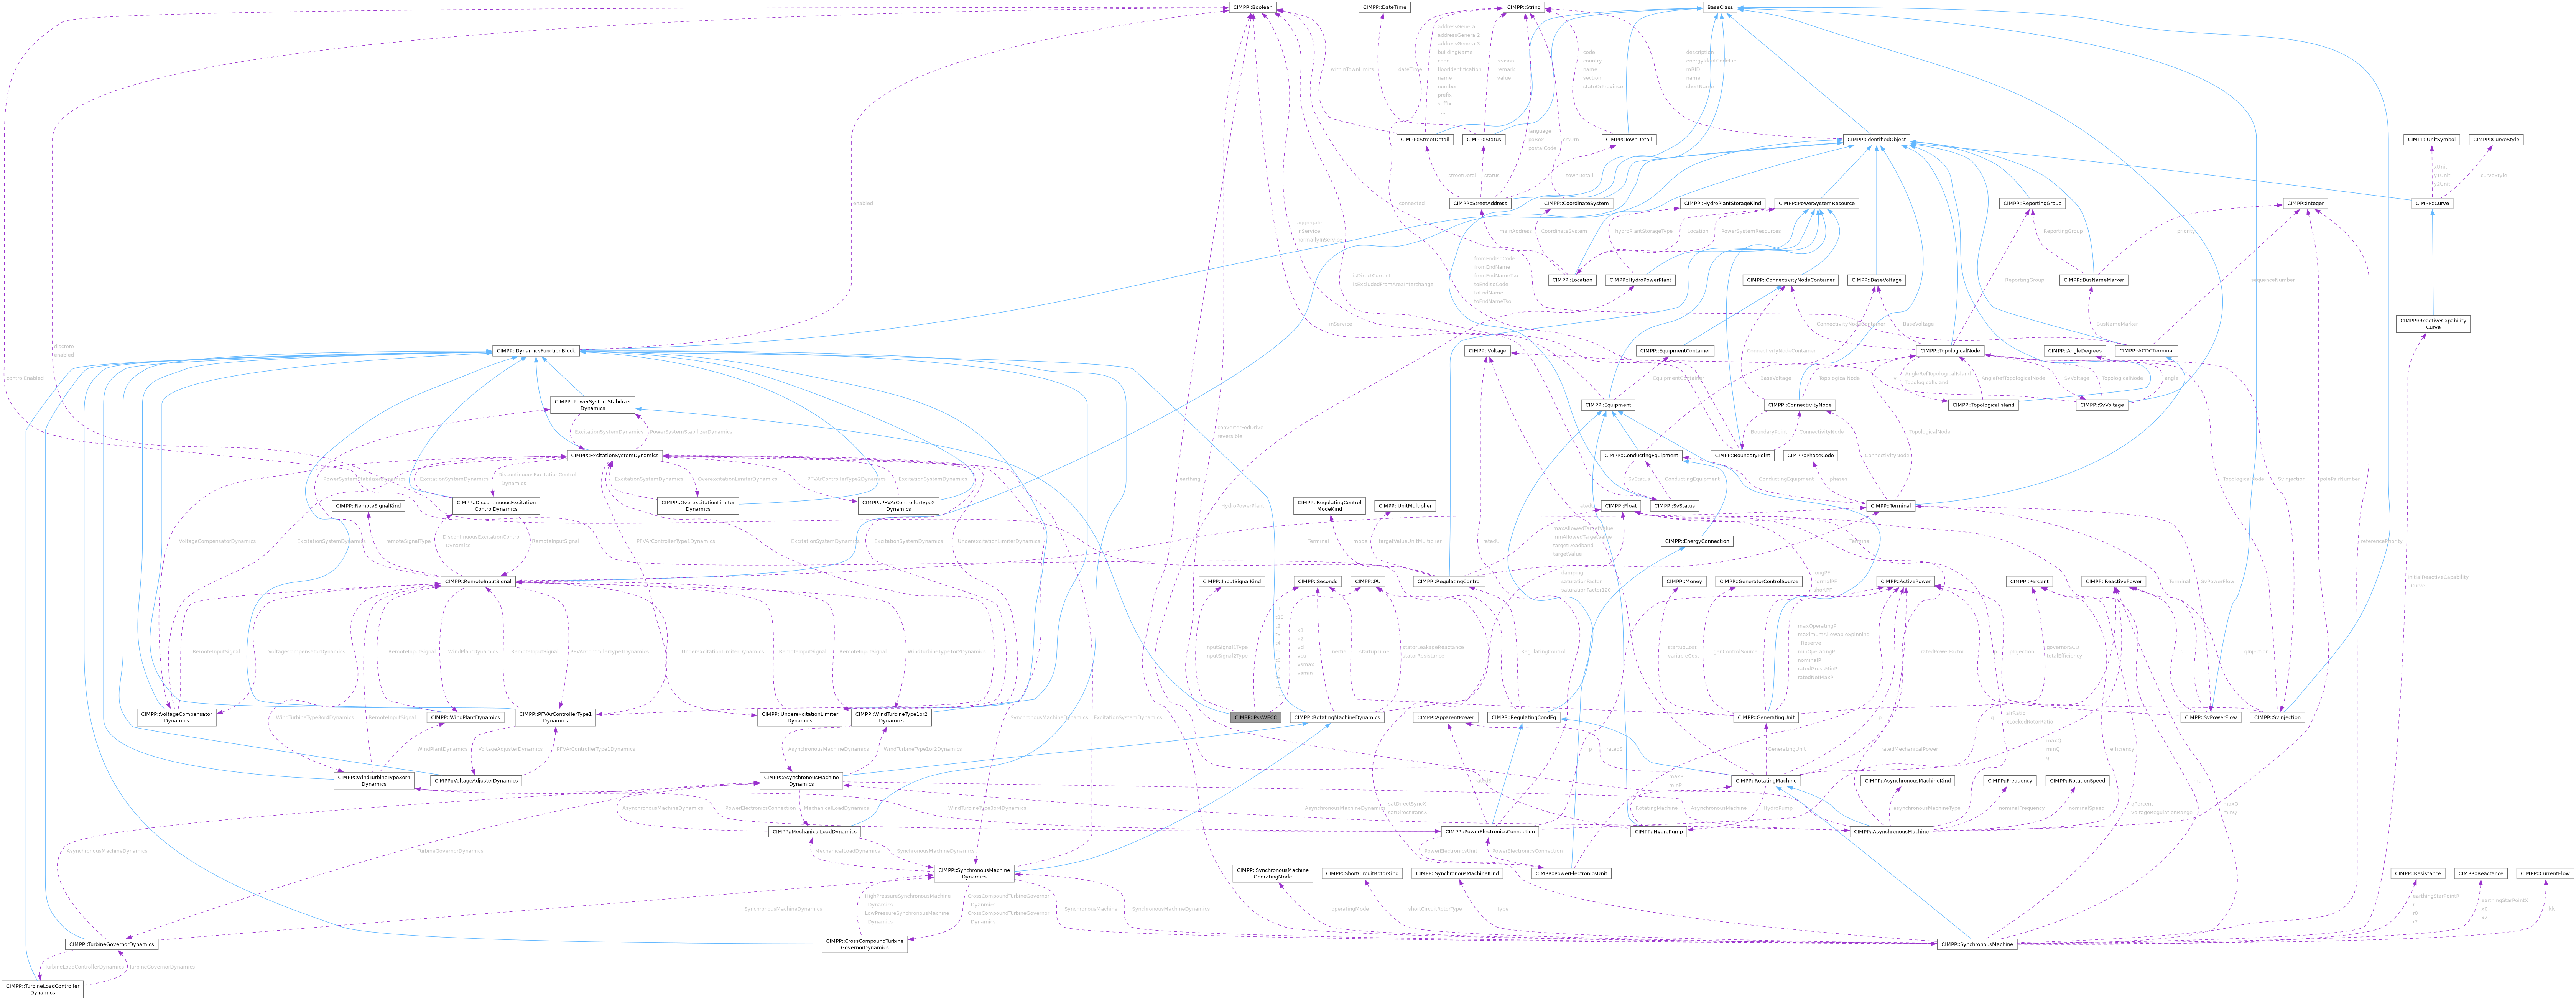
Dual input power system stabilizer, based on IEEE type 2, with modified output limiter defined by WECC (Western Electricity Coordinating Council, USA).
More...
|
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const CIMPP::BaseClassDefiner | declare () |
|
|
CIMPP::InputSignalKind | inputSignal1Type |
| | Type of input signal #1 (rotorAngularFrequencyDeviation, busFrequencyDeviation, generatorElectricalPower, generatorAcceleratingPower, busVoltage, or busVoltageDerivative - shall be different than PssWECC.inputSignal2Type). Typical value = rotorAngularFrequencyDeviation. Default: 0.
|
|
CIMPP::InputSignalKind | inputSignal2Type |
| | Type of input signal #2 (rotorAngularFrequencyDeviation, busFrequencyDeviation, generatorElectricalPower, generatorAcceleratingPower, busVoltage, busVoltageDerivative - shall be different than PssWECC.inputSignal1Type). Typical value = busVoltageDerivative. Default: 0.
|
|
CIMPP::PU | k1 |
| | Input signal 1 gain (K1). Typical value = 1,13. Default: 0.0.
|
|
CIMPP::PU | k2 |
| | Input signal 2 gain (K2). Typical value = 0,0. Default: 0.0.
|
|
CIMPP::Seconds | t1 |
| | Input signal 1 transducer time constant (T1) (>= 0). Typical value = 0,037. Default: 0.0.
|
|
CIMPP::Seconds | t10 |
| | Lag time constant (T10) (>= 0). Typical value = 0. Default: 0.0.
|
|
CIMPP::Seconds | t2 |
| | Input signal 2 transducer time constant (T2) (>= 0). Typical value = 0,0. Default: 0.0.
|
|
CIMPP::Seconds | t3 |
| | Stabilizer washout time constant (T3) (>= 0). Typical value = 9,5. Default: 0.0.
|
|
CIMPP::Seconds | t4 |
| | Stabilizer washout time lag constant (T4) (>= 0). Typical value = 9,5. Default: 0.0.
|
|
CIMPP::Seconds | t5 |
| | Lead time constant (T5) (>= 0). Typical value = 1,7. Default: 0.0.
|
|
CIMPP::Seconds | t6 |
| | Lag time constant (T6) (>= 0). Typical value = 1,5. Default: 0.0.
|
|
CIMPP::Seconds | t7 |
| | Lead time constant (T7) (>= 0). Typical value = 1,7. Default: 0.0.
|
|
CIMPP::Seconds | t8 |
| | Lag time constant (T8) (>= 0). Typical value = 1,5. Default: 0.0.
|
|
CIMPP::Seconds | t9 |
| | Lead time constant (T9) (>= 0). Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | vcl |
| | Minimum value for voltage compensator output (VCL). Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | vcu |
| | Maximum value for voltage compensator output (VCU). Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | vsmax |
| | Maximum output signal (Vsmax) (> PssWECC.vsmin). Typical value = 0,05. Default: 0.0.
|
|
CIMPP::PU | vsmin |
| | Minimum output signal (Vsmin) (< PssWECC.vsmax). Typical value = -0,05. Default: 0.0.
|
|
CIMPP::ExcitationSystemDynamics * | ExcitationSystemDynamics |
| | Excitation system model with which this power system stabilizer model is associated. Default: nullptr.
|
|
std::list< CIMPP::RemoteInputSignal * > | RemoteInputSignal |
| | Remote input signal used by this power system stabilizer model. Default: {}.
|
|
CIMPP::Boolean | enabled |
| | Function block used indicator. true = use of function block is enabled false = use of function block is disabled. Default: false.
|
|
std::list< CIMPP::DiagramObject * > | DiagramObjects |
| | The diagram objects that are associated with the domain object. Default: {}.
|
|
CIMPP::String | description |
| | The description is a free human readable text describing or naming the object. It may be non unique and may not correlate to a naming hierarchy. Default: "".
|
|
CIMPP::String | energyIdentCodeEic |
| | The attribute is used for an exchange of the EIC code (Energy identification Code). The length of the string is 16 characters as defined by the EIC code. For details on EIC scheme please refer to ENTSO-E web site. Default: "".
|
|
CIMPP::String | mRID |
| | Master resource identifier issued by a model authority. The mRID is unique within an exchange context. Global uniqueness is easily achieved by using a UUID, as specified in RFC 4122, for the mRID. The use of UUID is strongly recommended. For CIMXML data files in RDF syntax conforming to IEC 61970-552, the mRID is mapped to rdf:ID or rdf:about attributes that identify CIM object elements. Default: "".
|
|
CIMPP::String | name |
| | The name is any free human readable and possibly non unique text naming the object. Default: "".
|
|
CIMPP::String | shortName |
| | The attribute is used for an exchange of a human readable short name with length of the string 12 characters maximum. Default: "".
|
Dual input power system stabilizer, based on IEEE type 2, with modified output limiter defined by WECC (Western Electricity Coordinating Council, USA).

 1.15.0