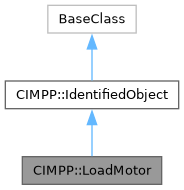
Aggregate induction motor load. This model is used to represent a fraction of an ordinary load as "induction motor load". It allows a load that is treated as an ordinary constant power in power flow analysis to be represented by an induction motor in dynamic simulation. This model is intended for representation of aggregations of many motors dispersed through a load represented at a high voltage bus but where there is no information on the characteristics of individual motors. Either a "one-cage" or "two-cage" model of the induction machine can be modelled. Magnetic saturation is not modelled. This model treats a fraction of the constant power part of a load as a motor. During initialisation, the initial power drawn by the motor is set equal to Pfrac times the constant P part of the static load. The remainder of the load is left as a static load. The reactive power demand of the motor is calculated during initialisation as a function of voltage at the load bus. This reactive power demand can be less than or greater than the constant Q component of the load. If the motor's reactive demand is greater than the constant Q component of the load, the model inserts a shunt capacitor at the terminal of the motor to bring its reactive demand down to equal the constant Q reactive load. If an induction motor load model and a static load model are both present for a load, the motor Pfrac is assumed to be subtracted from the power flow constant P load before the static load model is applied. The remainder of the load, if any, is then represented by the static load model.
More...
#include <LoadMotor.hpp>
|
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const CIMPP::BaseClassDefiner | declare () |
|
|
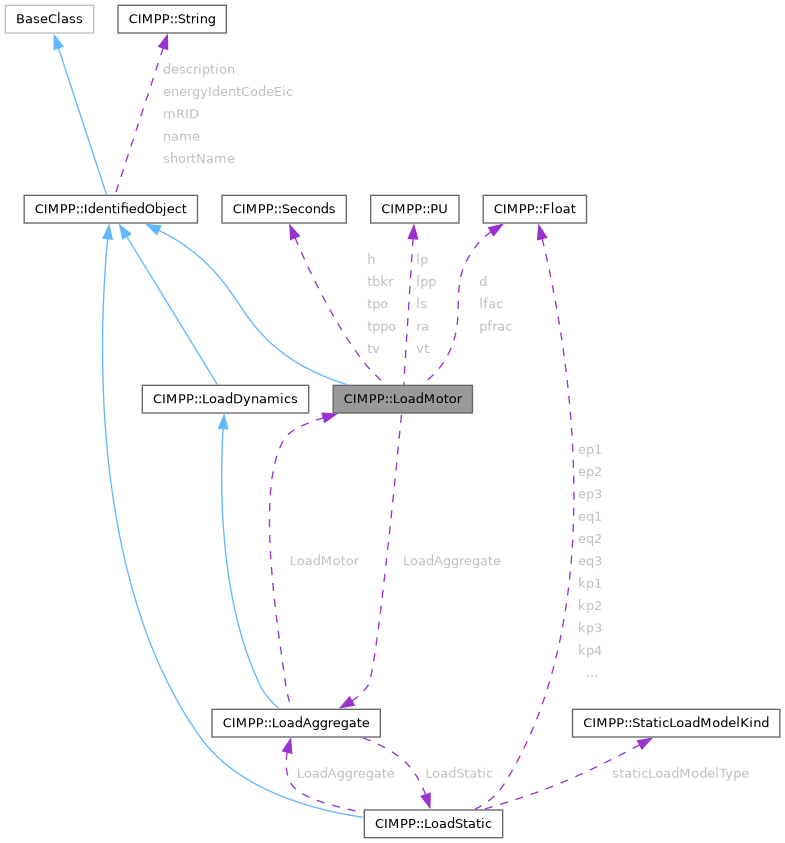
CIMPP::LoadAggregate * | LoadAggregate |
| | Aggregate load to which this aggregate motor (dynamic) load belongs. Default: nullptr.
|
|
CIMPP::Float | d |
| | Damping factor (D). Unit = delta P/delta speed. Typical value = 2. Default: 0.0.
|
|
CIMPP::Seconds | h |
| | Inertia constant (H) (>= 0). Typical value = 0,4. Default: 0.0.
|
|
CIMPP::Float | lfac |
| | Loading factor (Lfac). The ratio of initial P to motor MVA base. Typical value = 0,8. Default: 0.0.
|
|
CIMPP::PU | lp |
| | Transient reactance (Lp). Typical value = 0,15. Default: 0.0.
|
|
CIMPP::PU | lpp |
| | Subtransient reactance (Lpp). Typical value = 0,15. Default: 0.0.
|
|
CIMPP::PU | ls |
| | Synchronous reactance (Ls). Typical value = 3,2. Default: 0.0.
|
|
CIMPP::Float | pfrac |
| | Fraction of constant-power load to be represented by this motor model (Pfrac) (>= 0,0 and <= 1,0). Typical value = 0,3. Default: 0.0.
|
|
CIMPP::PU | ra |
| | Stator resistance (Ra). Typical value = 0. Default: 0.0.
|
|
CIMPP::Seconds | tbkr |
| | Circuit breaker operating time (Tbkr) (>= 0). Typical value = 0,08. Default: 0.0.
|
|
CIMPP::Seconds | tpo |
| | Transient rotor time constant (Tpo) (>= 0). Typical value = 1. Default: 0.0.
|
|
CIMPP::Seconds | tppo |
| | Subtransient rotor time constant (Tppo) (>= 0). Typical value = 0,02. Default: 0.0.
|
|
CIMPP::Seconds | tv |
| | Voltage trip pickup time (Tv) (>= 0). Typical value = 0,1. Default: 0.0.
|
|
CIMPP::PU | vt |
| | Voltage threshold for tripping (Vt). Typical value = 0,7. Default: 0.0.
|
|
std::list< CIMPP::DiagramObject * > | DiagramObjects |
| | The diagram objects that are associated with the domain object. Default: {}.
|
|
CIMPP::String | description |
| | The description is a free human readable text describing or naming the object. It may be non unique and may not correlate to a naming hierarchy. Default: "".
|
|
CIMPP::String | energyIdentCodeEic |
| | The attribute is used for an exchange of the EIC code (Energy identification Code). The length of the string is 16 characters as defined by the EIC code. For details on EIC scheme please refer to ENTSO-E web site. Default: "".
|
|
CIMPP::String | mRID |
| | Master resource identifier issued by a model authority. The mRID is unique within an exchange context. Global uniqueness is easily achieved by using a UUID, as specified in RFC 4122, for the mRID. The use of UUID is strongly recommended. For CIMXML data files in RDF syntax conforming to IEC 61970-552, the mRID is mapped to rdf:ID or rdf:about attributes that identify CIM object elements. Default: "".
|
|
CIMPP::String | name |
| | The name is any free human readable and possibly non unique text naming the object. Default: "".
|
|
CIMPP::String | shortName |
| | The attribute is used for an exchange of a human readable short name with length of the string 12 characters maximum. Default: "".
|
|
|
static const char | debugName [] = "LoadMotor" |
|
static const char | debugName [] = "IdentifiedObject" |
|
static const char | debugName [] = "BaseClass" |
Aggregate induction motor load. This model is used to represent a fraction of an ordinary load as "induction motor load". It allows a load that is treated as an ordinary constant power in power flow analysis to be represented by an induction motor in dynamic simulation. This model is intended for representation of aggregations of many motors dispersed through a load represented at a high voltage bus but where there is no information on the characteristics of individual motors. Either a "one-cage" or "two-cage" model of the induction machine can be modelled. Magnetic saturation is not modelled. This model treats a fraction of the constant power part of a load as a motor. During initialisation, the initial power drawn by the motor is set equal to Pfrac times the constant P part of the static load. The remainder of the load is left as a static load. The reactive power demand of the motor is calculated during initialisation as a function of voltage at the load bus. This reactive power demand can be less than or greater than the constant Q component of the load. If the motor's reactive demand is greater than the constant Q component of the load, the model inserts a shunt capacitor at the terminal of the motor to bring its reactive demand down to equal the constant Q reactive load. If an induction motor load model and a static load model are both present for a load, the motor Pfrac is assumed to be subtracted from the power flow constant P load before the static load model is applied. The remainder of the load, if any, is then represented by the static load model.
◆ addClassGetFnsToMap()
| void LoadMotor::addClassGetFnsToMap |
( |
std::map< std::string, class_get_function > & | get_map | ) |
const |
|
overridevirtual |
◆ addEnumGetFnsToMap()
| void LoadMotor::addEnumGetFnsToMap |
( |
std::map< std::string, get_function > & | get_map | ) |
const |
|
overridevirtual |
◆ addPrimitiveGetFnsToMap()
| void LoadMotor::addPrimitiveGetFnsToMap |
( |
std::map< std::string, get_function > & | get_map | ) |
const |
|
overridevirtual |
◆ allAttrDetailsMap()
| std::map< std::string, AttrDetails > LoadMotor::allAttrDetailsMap |
( |
| ) |
const |
|
overrideprotectedvirtual |
◆ debugString()
| const char * LoadMotor::debugString |
( |
| ) |
const |
|
overridevirtual |
◆ getAttributeNames()
| const std::list< std::string > & LoadMotor::getAttributeNames |
( |
| ) |
const |
|
overridevirtual |
◆ getAttributeNamespaceUrl()
| const std::string & LoadMotor::getAttributeNamespaceUrl |
( |
const std::string & | attrName | ) |
const |
|
overridevirtual |
◆ getClassNamespaceUrl()
| const std::string & LoadMotor::getClassNamespaceUrl |
( |
| ) |
const |
|
overridevirtual |
◆ getPossibleAttributeProfiles()
| const std::list< CGMESProfile > & LoadMotor::getPossibleAttributeProfiles |
( |
const std::string & | attrName | ) |
const |
|
overridevirtual |
◆ getPossibleProfiles()
| const std::list< CGMESProfile > & LoadMotor::getPossibleProfiles |
( |
| ) |
const |
|
overridevirtual |
◆ getPossibleProfilesIncludingAttributes()
| const std::list< CGMESProfile > & LoadMotor::getPossibleProfilesIncludingAttributes |
( |
| ) |
const |
|
overridevirtual |
◆ getRecommendedProfile()
| const CGMESProfile & LoadMotor::getRecommendedProfile |
( |
| ) |
const |
|
overridevirtual |
◆ isAssignableFrom()
| bool LoadMotor::isAssignableFrom |
( |
BaseClass * | otherObject | ) |
const |
|
overridevirtual |
The documentation for this class was generated from the following files:

 1.15.0