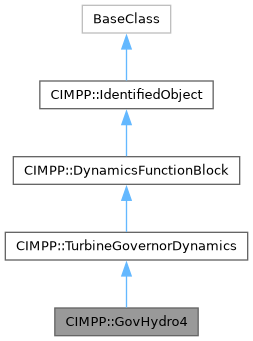
Hydro turbine and governor. Represents plants with straight-forward penstock configurations and hydraulic governors of the traditional 'dashpot' type. This model can be used to represent simple, Francis/Pelton or Kaplan turbines.
More...
|
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const BaseClassDefiner | declare () |
|
static void | addConstructToMap (std::unordered_map< std::string, BaseClass *(*)()> &factory_map) |
|
static void | addPrimitiveAssignFnsToMap (std::unordered_map< std::string, assign_function > &assign_map) |
|
static void | addClassAssignFnsToMap (std::unordered_map< std::string, class_assign_function > &assign_map) |
|
static const CIMPP::BaseClassDefiner | declare () |
|
|
CIMPP::PU | at |
| | Turbine gain (At). Typical value = 1,2. Default: 0.0.
|
|
CIMPP::PU | bgv0 |
| | Kaplan blade servo point 0 (Bgv0) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 0. Default: 0.0.
|
|
CIMPP::PU | bgv1 |
| | Kaplan blade servo point 1 (Bgv1) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 0. Default: 0.0.
|
|
CIMPP::PU | bgv2 |
| | Kaplan blade servo point 2 (Bgv2) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 0,1. Default: 0.0.
|
|
CIMPP::PU | bgv3 |
| | Kaplan blade servo point 3 (Bgv3) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 0,667. Default: 0.0.
|
|
CIMPP::PU | bgv4 |
| | Kaplan blade servo point 4 (Bgv4) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 0,9. Default: 0.0.
|
|
CIMPP::PU | bgv5 |
| | Kaplan blade servo point 5 (Bgv5) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 1. Default: 0.0.
|
|
CIMPP::Float | bmax |
| | Maximum blade adjustment factor (Bmax) (= 0 for simple, = 0 for Francis/Pelton). Typical value for Kaplan = 1,1276. Default: 0.0.
|
|
CIMPP::Frequency | db1 |
| | Intentional deadband width (db1). Unit = Hz. Typical value = 0. Default: 0.0.
|
|
CIMPP::ActivePower | db2 |
| | Unintentional dead-band (db2). Unit = MW. Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | dturb |
| | Turbine damping factor (Dturb). Unit = delta P (PU of MWbase) / delta speed (PU). Typical value for simple = 0,5, Francis/Pelton = 1,1, Kaplan = 1,1. Default: 0.0.
|
|
CIMPP::Frequency | eps |
| | Intentional db hysteresis (eps). Unit = Hz. Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | gmax |
| | Maximum gate opening, PU of MWbase (Gmax) (> GovHydro4.gmin). Typical value = 1. Default: 0.0.
|
|
CIMPP::PU | gmin |
| | Minimum gate opening, PU of MWbase (Gmin) (< GovHydro4.gmax). Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | gv0 |
| | Nonlinear gain point 0, PU gv (Gv0) (= 0 for simple). Typical for Francis/Pelton = 0,1, Kaplan = 0,1. Default: 0.0.
|
|
CIMPP::PU | gv1 |
| | Nonlinear gain point 1, PU gv (Gv1) (= 0 for simple, > GovHydro4.gv0 for Francis/Pelton and Kaplan). Typical value for Francis/Pelton = 0,4, Kaplan = 0,4. Default: 0.0.
|
|
CIMPP::PU | gv2 |
| | Nonlinear gain point 2, PU gv (Gv2) (= 0 for simple, > GovHydro4.gv1 for Francis/Pelton and Kaplan). Typical value for Francis/Pelton = 0,5, Kaplan = 0,5. Default: 0.0.
|
|
CIMPP::PU | gv3 |
| | Nonlinear gain point 3, PU gv (Gv3) (= 0 for simple, > GovHydro4.gv2 for Francis/Pelton and Kaplan). Typical value for Francis/Pelton = 0,7, Kaplan = 0,7. Default: 0.0.
|
|
CIMPP::PU | gv4 |
| | Nonlinear gain point 4, PU gv (Gv4) (= 0 for simple, > GovHydro4.gv3 for Francis/Pelton and Kaplan). Typical value for Francis/Pelton = 0,8, Kaplan = 0,8. Default: 0.0.
|
|
CIMPP::PU | gv5 |
| | Nonlinear gain point 5, PU gv (Gv5) (= 0 for simple, < 1 and > GovHydro4.gv4 for Francis/Pelton and Kaplan). Typical value for Francis/Pelton = 0,9, Kaplan = 0,9. Default: 0.0.
|
|
CIMPP::PU | hdam |
| | Head available at dam (hdam). Typical value = 1. Default: 0.0.
|
|
CIMPP::GovHydro4ModelKind | model |
| | The kind of model being represented (simple, Francis/Pelton or Kaplan). Default: 0.
|
|
CIMPP::ActivePower | mwbase |
| | Base for power values (MWbase) (> 0). Unit = MW. Default: 0.0.
|
|
CIMPP::PU | pgv0 |
| | Nonlinear gain point 0, PU power (Pgv0) (= 0 for simple). Typical value = 0. Default: 0.0.
|
|
CIMPP::PU | pgv1 |
| | Nonlinear gain point 1, PU power (Pgv1) (= 0 for simple). Typical value for Francis/Pelton = 0,42, Kaplan = 0,35. Default: 0.0.
|
|
CIMPP::PU | pgv2 |
| | Nonlinear gain point 2, PU power (Pgv2) (= 0 for simple). Typical value for Francis/Pelton = 0,56, Kaplan = 0,468. Default: 0.0.
|
|
CIMPP::PU | pgv3 |
| | Nonlinear gain point 3, PU power (Pgv3) (= 0 for simple). Typical value for Francis/Pelton = 0,8, Kaplan = 0,796. Default: 0.0.
|
|
CIMPP::PU | pgv4 |
| | Nonlinear gain point 4, PU power (Pgv4) (= 0 for simple). Typical value for Francis/Pelton = 0,9, Kaplan = 0,917. Default: 0.0.
|
|
CIMPP::PU | pgv5 |
| | Nonlinear gain point 5, PU power (Pgv5) (= 0 for simple). Typical value for Francis/Pelton = 0,97, Kaplan = 0,99. Default: 0.0.
|
|
CIMPP::PU | qnl |
| | No-load flow at nominal head (Qnl). Typical value for simple = 0,08, Francis/Pelton = 0, Kaplan = 0. Default: 0.0.
|
|
CIMPP::Seconds | rperm |
| | Permanent droop (Rperm) (>= 0). Typical value = 0,05. Default: 0.0.
|
|
CIMPP::Seconds | rtemp |
| | Temporary droop (Rtemp) (>= 0). Typical value = 0,3. Default: 0.0.
|
|
CIMPP::Seconds | tblade |
| | Blade servo time constant (Tblade) (>= 0). Typical value = 100. Default: 0.0.
|
|
CIMPP::Seconds | tg |
| | Gate servo time constant (Tg) (> 0). Typical value = 0,5. Default: 0.0.
|
|
CIMPP::Seconds | tp |
| | Pilot servo time constant (Tp) (>= 0). Typical value = 0,1. Default: 0.0.
|
|
CIMPP::Seconds | tr |
| | Dashpot time constant (Tr) (>= 0). Typical value = 5. Default: 0.0.
|
|
CIMPP::Seconds | tw |
| | Water inertia time constant (Tw) (> 0). Typical value = 1. Default: 0.0.
|
|
CIMPP::Float | uc |
| | Max gate closing velocity (Uc). Typical value = 0,2. Default: 0.0.
|
|
CIMPP::Float | uo |
| | Max gate opening velocity (Uo). Typical value = 0,2. Default: 0.0.
|
|
CIMPP::AsynchronousMachineDynamics * | AsynchronousMachineDynamics |
| | Asynchronous machine model with which this turbine-governor model is associated. TurbineGovernorDynamics shall have either an association to SynchronousMachineDynamics or to AsynchronousMachineDynamics. Default: nullptr.
|
|
CIMPP::SynchronousMachineDynamics * | SynchronousMachineDynamics |
| | Synchronous machine model with which this turbine-governor model is associated. TurbineGovernorDynamics shall have either an association to SynchronousMachineDynamics or to AsynchronousMachineDynamics. Default: nullptr.
|
|
CIMPP::TurbineLoadControllerDynamics * | TurbineLoadControllerDynamics |
| | Turbine load controller providing input to this turbine-governor. Default: nullptr.
|
|
CIMPP::Boolean | enabled |
| | Function block used indicator. true = use of function block is enabled false = use of function block is disabled. Default: false.
|
|
std::list< CIMPP::DiagramObject * > | DiagramObjects |
| | The diagram objects that are associated with the domain object. Default: {}.
|
|
CIMPP::String | description |
| | The description is a free human readable text describing or naming the object. It may be non unique and may not correlate to a naming hierarchy. Default: "".
|
|
CIMPP::String | energyIdentCodeEic |
| | The attribute is used for an exchange of the EIC code (Energy identification Code). The length of the string is 16 characters as defined by the EIC code. For details on EIC scheme please refer to ENTSO-E web site. Default: "".
|
|
CIMPP::String | mRID |
| | Master resource identifier issued by a model authority. The mRID is unique within an exchange context. Global uniqueness is easily achieved by using a UUID, as specified in RFC 4122, for the mRID. The use of UUID is strongly recommended. For CIMXML data files in RDF syntax conforming to IEC 61970-552, the mRID is mapped to rdf:ID or rdf:about attributes that identify CIM object elements. Default: "".
|
|
CIMPP::String | name |
| | The name is any free human readable and possibly non unique text naming the object. Default: "".
|
|
CIMPP::String | shortName |
| | The attribute is used for an exchange of a human readable short name with length of the string 12 characters maximum. Default: "".
|
Hydro turbine and governor. Represents plants with straight-forward penstock configurations and hydraulic governors of the traditional 'dashpot' type. This model can be used to represent simple, Francis/Pelton or Kaplan turbines.

 1.15.0